Selected work
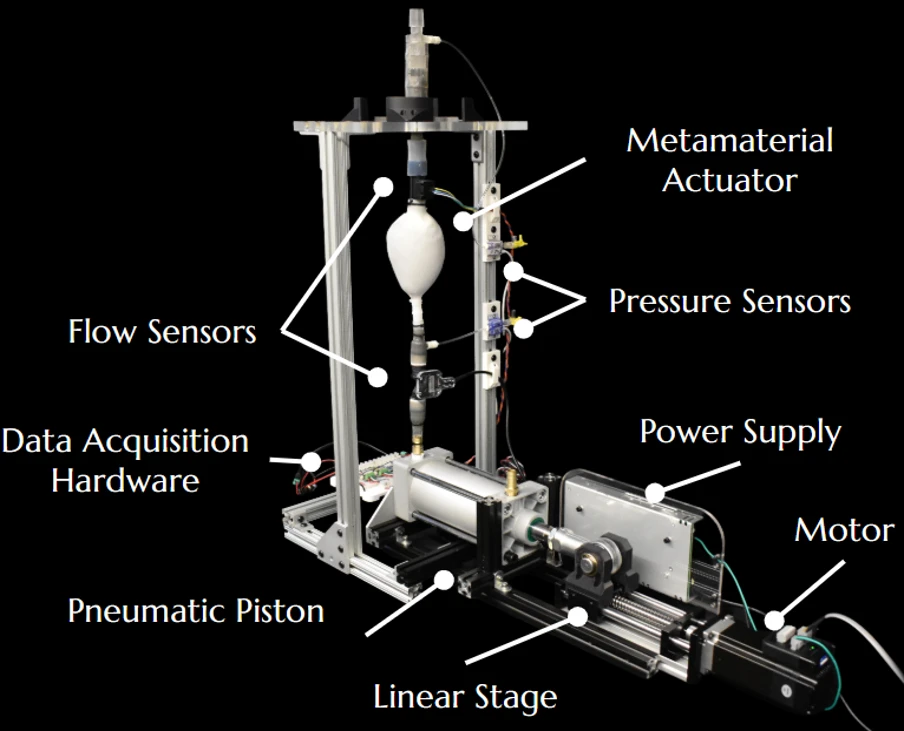
System ID of a Metamaterial Soft Robotic Ventricle
A benchtop platform for identifying the pressure and flow dynamics of a 3D-printed metamaterial left ventricle. I designed and built the servo-driven piston pump that drives it.
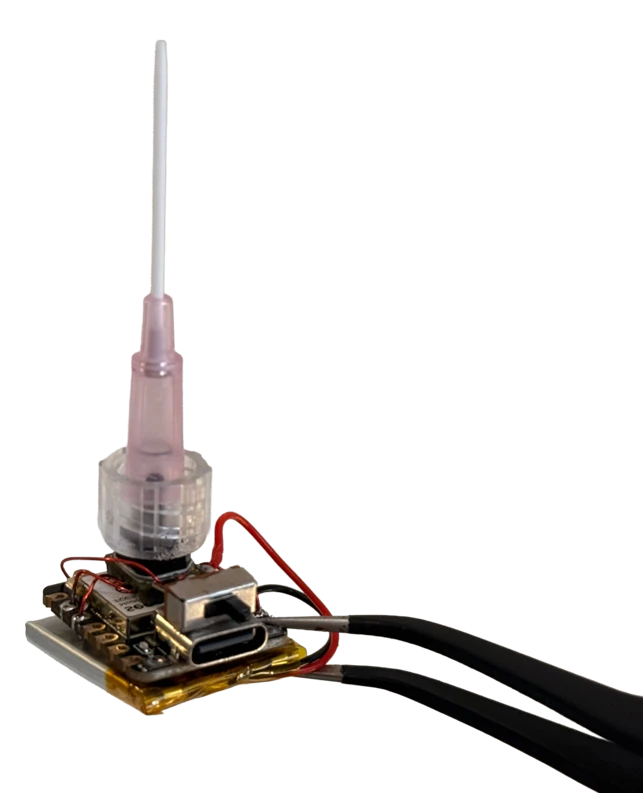
Continuous Intramuscular Compartment Pressure Monitoring Device
An open-source wearable that measures intracompartmental pressure continuously through any standard needle and alerts a clinician's phone when it crosses a threshold. Built from $40 of off-the-shelf parts with a clinician at MGH.
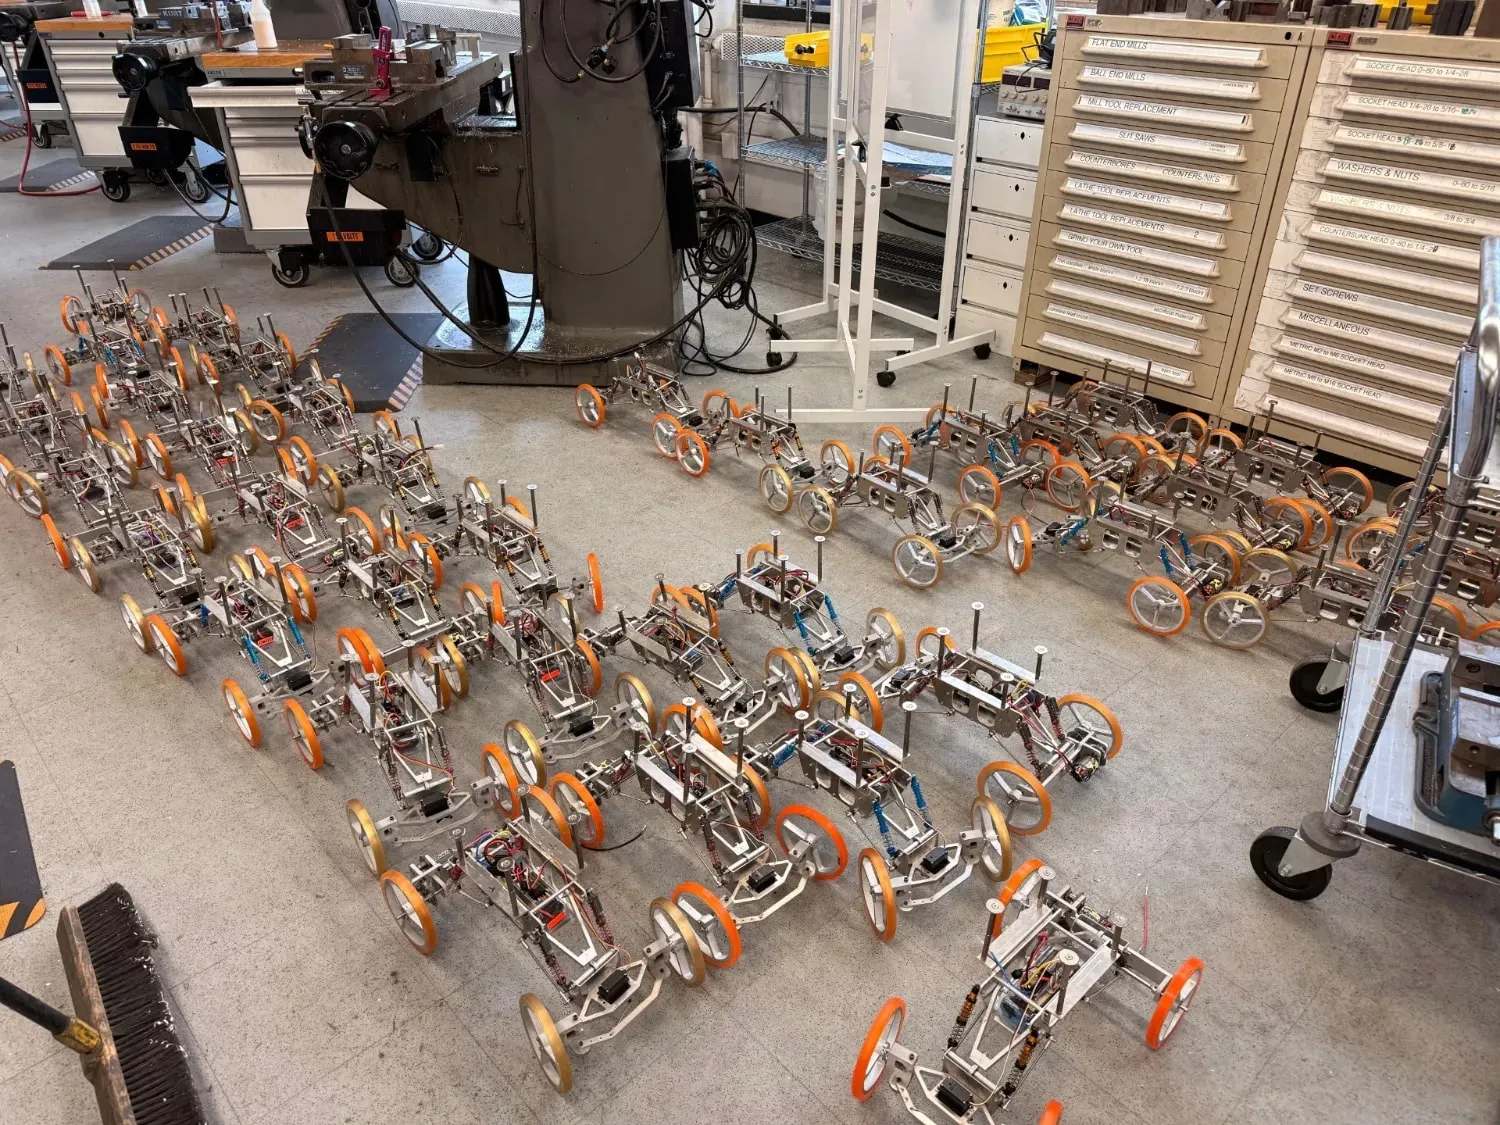
RC Car Steering, Designed for Manufacturing
Re-engineering an RC car steering system for batch production. 3D geometries flattened into waterjet-cut aluminum profiles, with tight tolerances only where the mechanism needs them.
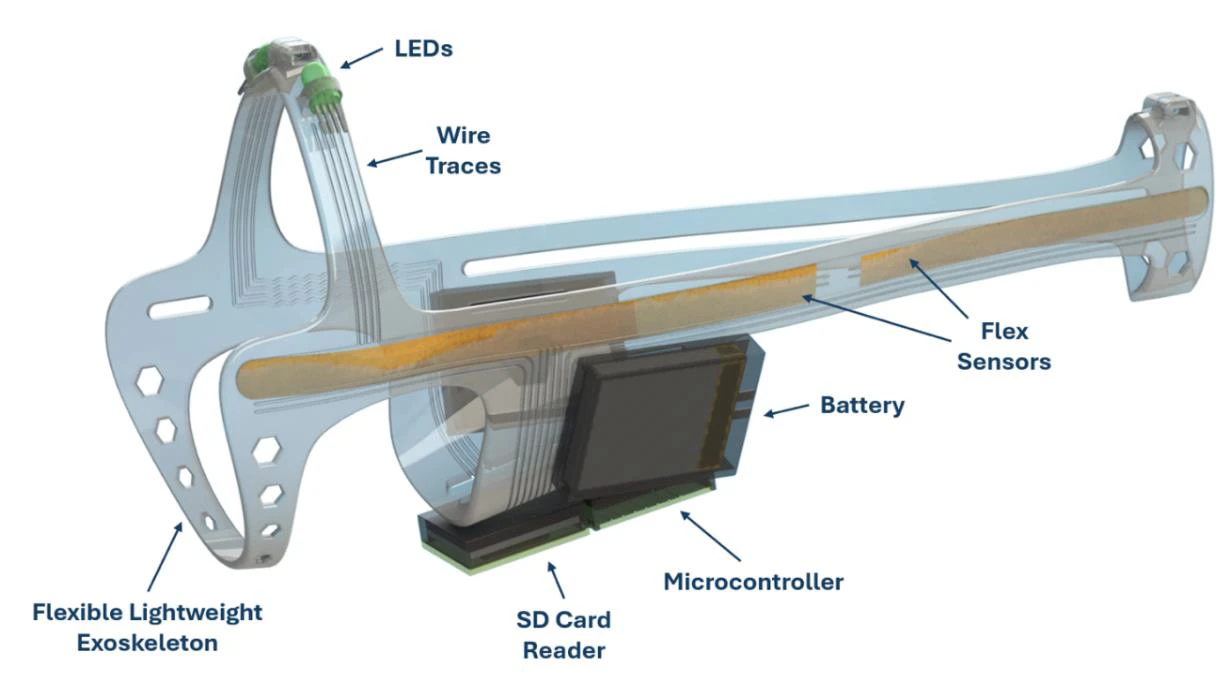
ExoTic, a Smart Fish Exoskeleton
A non-invasive, sensor-laden exoskeleton for free-swimming fish. A flexible 3D-printed harness carries flex sensors, an IMU, onboard logging and posture-reactive LEDs, built around a 5%-of-body-weight limit.
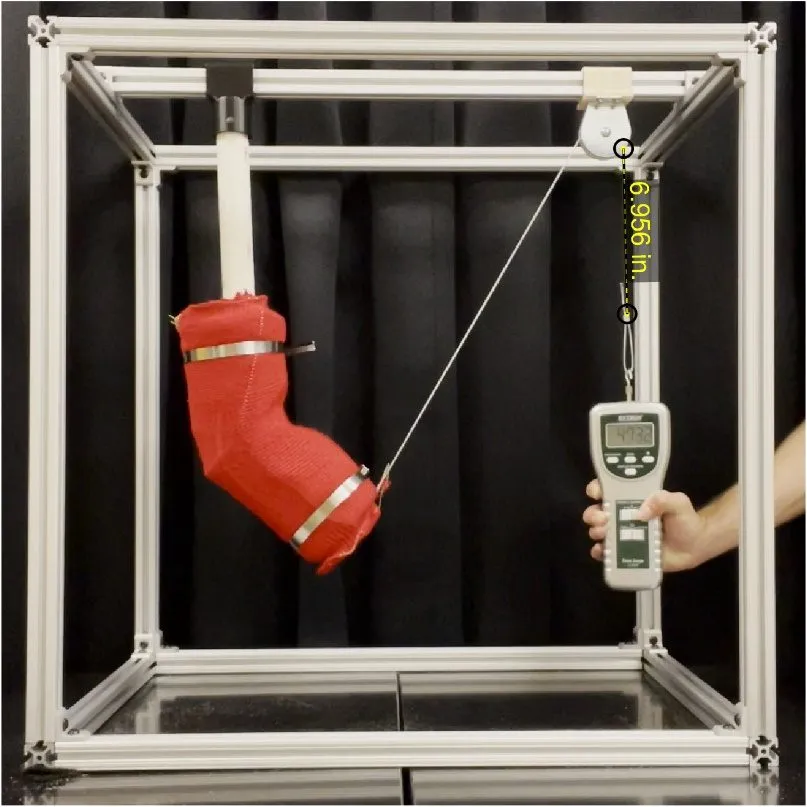
ExoSkins, Programmable Knitted Orthoses
Knitted knee orthoses whose stiffness is programmed by stitch pattern alone. I built the knee-flexion test rig and ran every torque-angle experiment for this co-first-author paper.
Elephant Skin Mechanics
Full-field strain measurement of elephant skin with digital image correlation, for insight into soft-tissue mechanics that informs biomimetic materials and robotics.
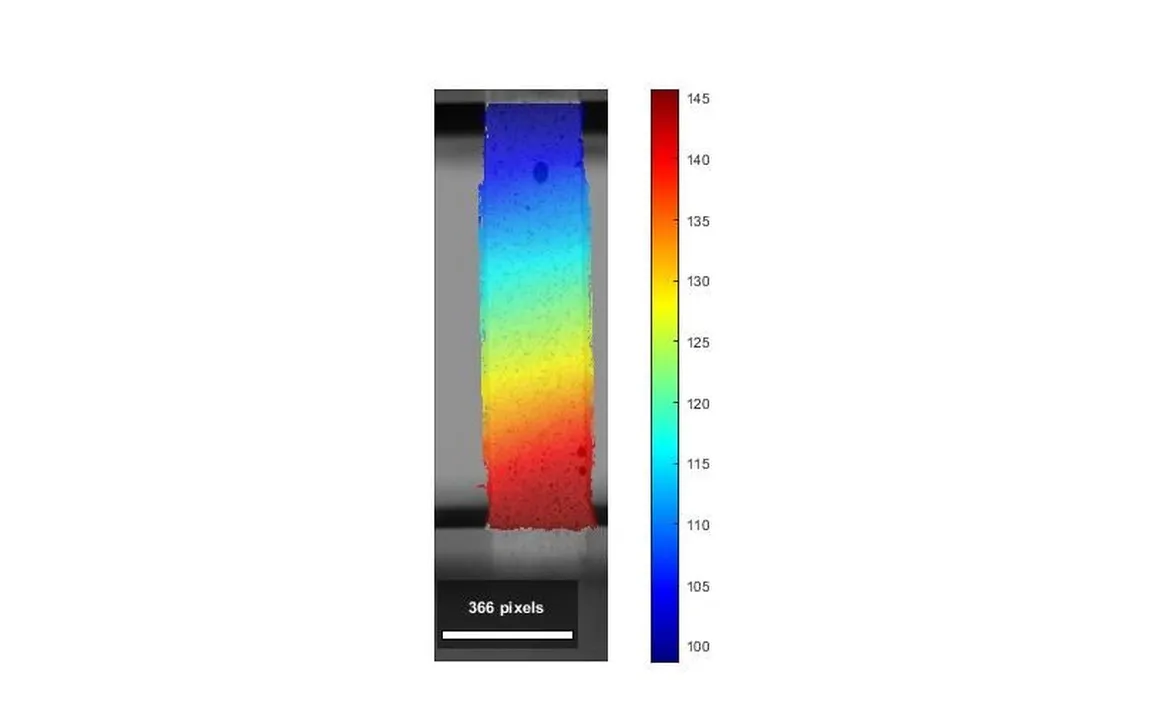
Metal AM Process Characterization
Mechanical characterization of additively manufactured 15-5PH stainless steel across process parameters, using DIC strain measurement and computer-vision porosity analysis.
Publications
Google Scholar-
[1]
Read
Augmenting knee biomechanics through programmable knitted ExoSkin orthoses
arXiv:2509.22971 · 2025 · *Equal contribution